Recovery System
Fault-tolerant recovery avionics with triple-MCU voting and ten high-current deployment channels
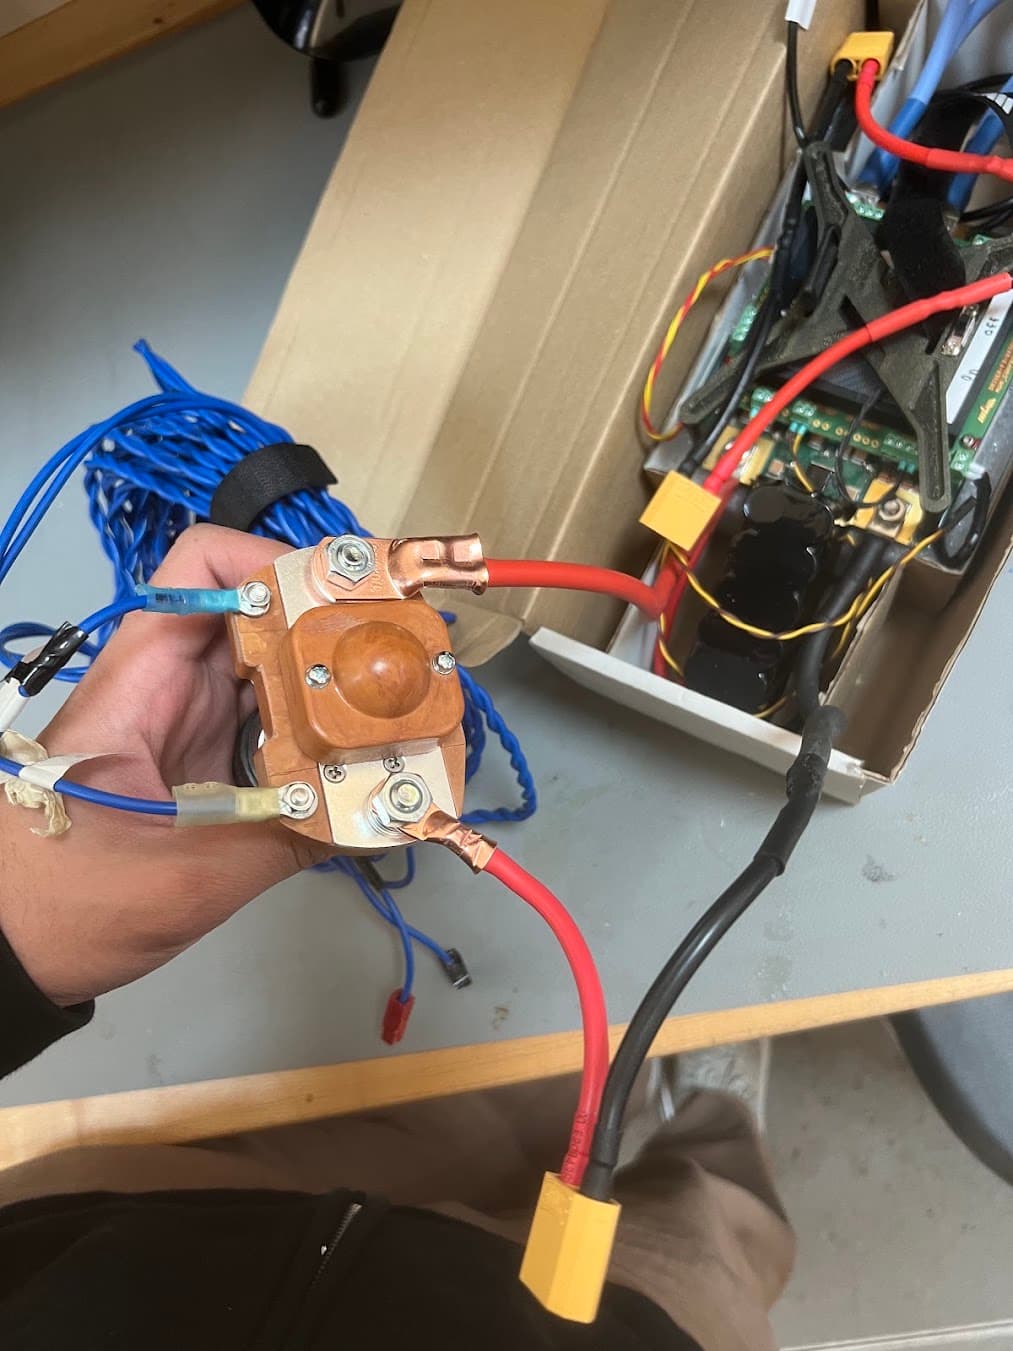
A six-layer recovery controller built around two power trees, three independent STM32 domains, hardware voting, local sensing, and ten 24 V deployment channels. I owned the board end to end, from architecture and layout through bring-up and the full ten-channel deployment test.
- Role
- Design Responsible Engineer
- Board
- 6 layers
- Tools
- Altium, Oscilloscope, Electronic Load, Bench Supply
AvionicsRecoveryVoting LogicRedundant ControlHigh CurrentAltium